Sarvagya
Singh
Building high-performance web applications and design systems. Specialized in frontend architecture, TypeScript ecosystems, and scaling user interfaces for millions of users.
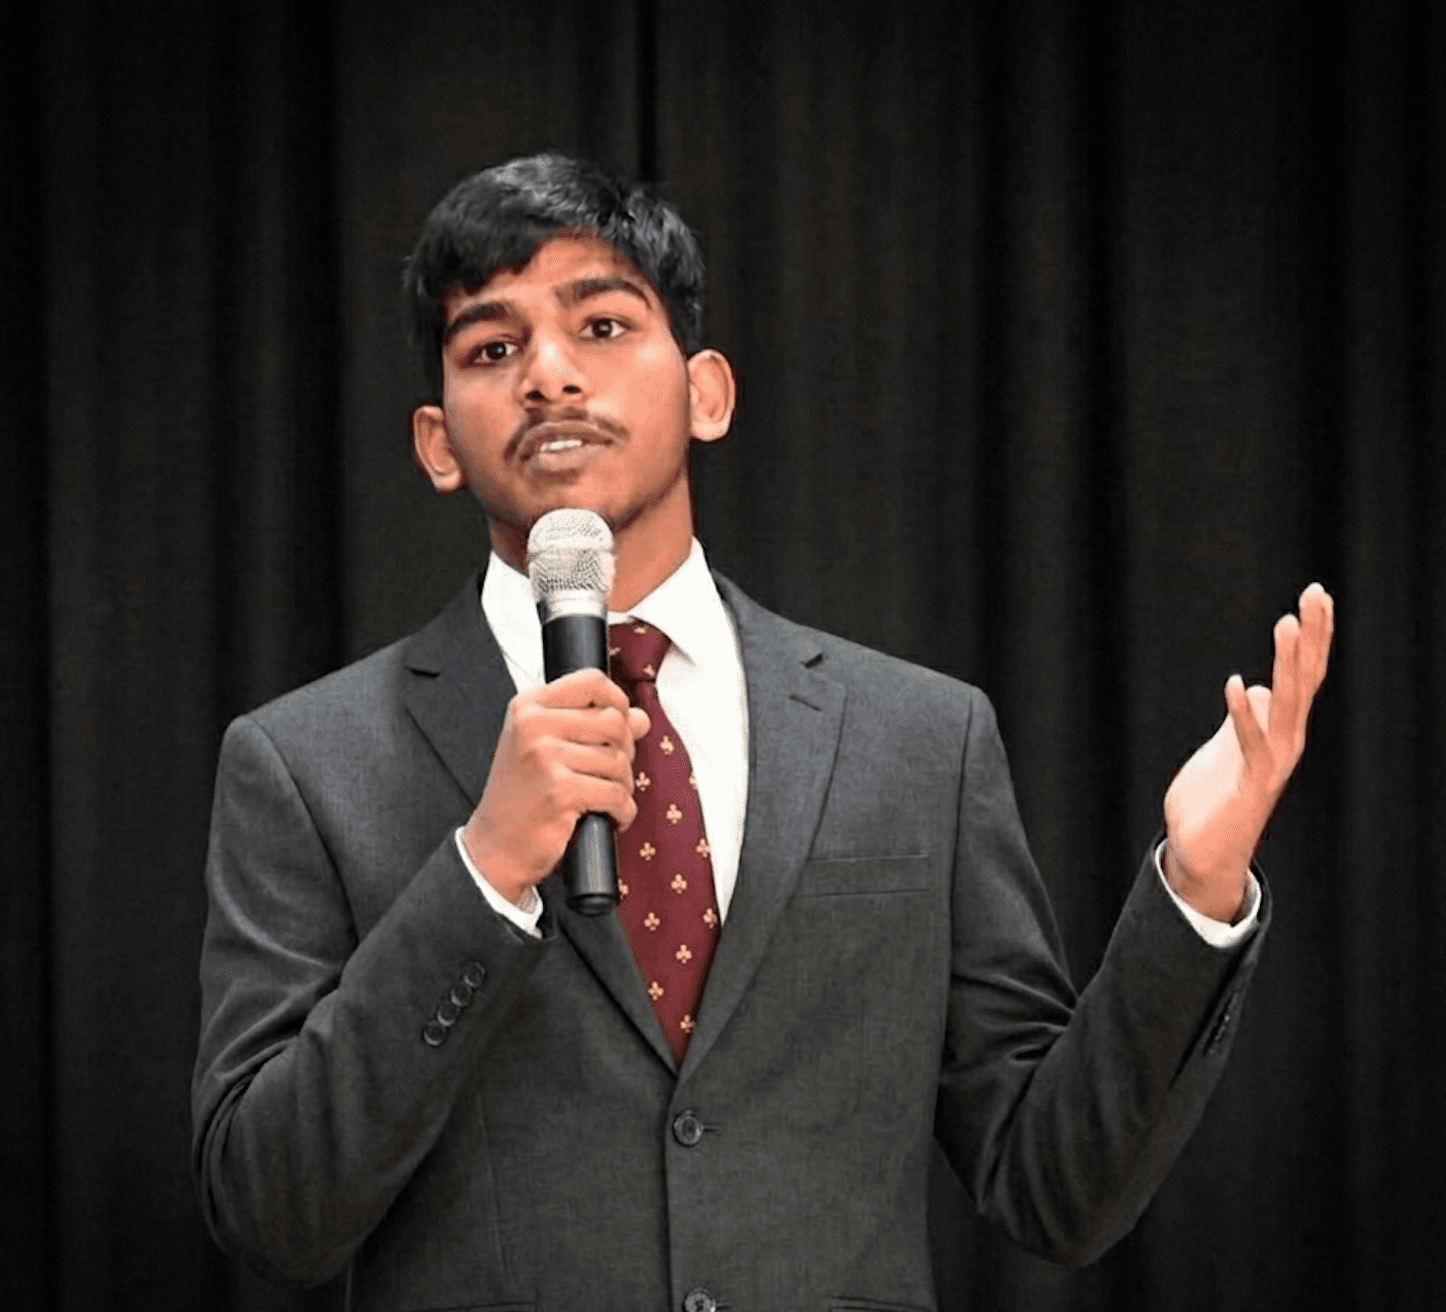
I’m Sarvagya.
I’m a first-year Computer Science student at the University of St Andrews. I grew up in Bokaro Steel City and went to Delhi Public School there, where most of my projects began with a practical problem and very little hardware to solve it with.
I’m drawn to the place where machine learning meets constraints: a physics-informed surrogate for photon transport, a retrieval-augmented LLM with a safety-validation layer, and a livestock-health model small enough to run on a Cortex-M4 collar.
At St Andrews I’m the Freshers’ Representative on the Computing Society committee and a member of the Formula Student AI team, writing perception and control software for an autonomous racing car.
Class XII 93% · Class X 96.8% · SAT 1520 · Blaise Pascal Gold Medal, DPS Bokaro
Engineered for
Computational Rigor.
AI & Machine Learning
Physics-Informed & Safety-Validated
Edge Computing & IoT
Real-World Deployment
Robotics & Computer Vision
Autonomous Systems
Languages & Backend
Core Tooling
Systems Built
Under Constraints.
Nandani: Edge-AIoT Livestock Health Platform
Lead Engineer • Team of 3
Compressed an LSTM anomaly detector onto a Cortex-M4 collar (256 KB RAM, under 10 mW). Architected offline-first MQTT + SQLite sync for intermittent 2G and deployed across 40+ smallholder farms, with IIT (ISM) on hardware.
Key Result 01
40+ Farms Deployed
Key Result 02
40% Fewer False Positives
Key Result 03
National Rank 2 • NIT Conclave
PulseAge: Multimodal Cardiac Diagnosis Support
Team of 3
ResNet-50 + EfficientNet-B4 ensemble fusing ECG and cardiac MRI to flag hypertrophic cardiomyopathy. Handles 1:8 class imbalance with focal loss, with sub-200 ms inference on GPU-free hardware after INT8 quantization.
Key Result 01
Sub-200 ms Inference
Key Result 02
ECG + cMRI Fusion
Key Result 03
1:8 Imbalance Handled
Autonomous Inspection Rover
Navigation & CV Lead • Team of 3
ROS2 rover with LiDAR–camera EKF fusion and A*/DWA path planning, plus TensorRT-accelerated YOLO. Led navigation and computer vision integration.
Key Result 01
All-India Rank 15
Key Result 02
35 FPS YOLO
Key Result 03
Under 50 ms Latency
Blue Ocean: Multi-Agent Market & Regulatory Intelligence
Solo Project
Multi-agent system (Gemini 3 Pro) that tracks competitor activity and regulatory change, with an RSS ingestion pipeline over 10+ sources accelerated with NVIDIA RAPIDS.
Key Result 01
Top 10 of 1,500+ Teams
Key Result 02
10+ Sources Ingested
Key Result 03
Google GenAI Hackathon APAC
Selected Work.
UNESCO International Year of Quantum Science
Manuscript submitted May 2026 • Sole author • 2026
PhotonPINN3D: Physics-Informed Surrogate for Monte Carlo Photon Transport
An ensemble of three PINNs (550, 650, 800 nm) with a Beer-Lambert log-prior and variance-weighted training data. Validated against a 5-seed, 10^6-photon Monte Carlo reference at 4.7% far-field MAPE, with 117× faster CPU inference. Adopted as a forward solver for diffuse optical tomography and fNIRS sensitivity maps.
NUS
AI in Healthcare • 2024
PromptBiotics: Retrieval-Augmented LLM with Safety Validation
A RAG system on fine-tuned GPT-4o with hybrid BM25 + semantic retrieval and cross-encoder reranking. A constraint-based validation layer checks outputs against WHO dietary guidelines and cut hallucinations by 60%. Shipped a beta to 500+ users.
Leadership
& Teams.
Sept 2026 — Present
Freshers' Representative
Computing Society, St Andrews
Sole first-year voice on the committee, representing a 200+ first-year cohort. Steers decisions on society events, hackathons and university team selections from direct cohort feedback.
Output_Log
- 200+ Student Cohort
- Sole First-Year Voice
- Events & Info Sessions
Sept 2026 — Present
Technical Team Member
Formula Student AI, St Andrews
Developing perception and control software for the team's fully autonomous racing car.
Output_Log
- Perception
- Control Software
- Autonomous Racing
2023 — 2024
Lead Engineer
Nandani — Edge-AIoT Platform
Directed a 3-person team shipping a livestock health platform to 40+ farms. Owned system architecture and delivery alongside the IIT (ISM) hardware collaboration.
Output_Log
- Team of 3
- 40+ Farms
- IIT (ISM) Collaboration
2024
Navigation & CV Lead
Autonomous Inspection Rover
Led navigation and computer vision integration on a ROS2 autonomous rover. The team ranked All-India 15th at WRO Nationals.
Output_Log
- Team of 3
- ROS2
- All-India Rank 15
Milestones that define me.
UNESCO Quantum Science Competition
Best Scientific Creativity Award (global top prize) for PhotonPINN3D, a physics-informed surrogate for Monte Carlo photon transport with 117× faster CPU inference.
Google GenAI Hackathon APAC
Designed Blue Ocean solo: a multi-agent system (Gemini 3 Pro) tracking competitor activity and regulatory change across 10+ RSS sources.
World Robot Olympiad Nationals
Led navigation and computer vision on a ROS2 inspection rover using LiDAR–camera fusion and TensorRT-accelerated YOLO.
NIT Industry Academia Conclave
National recognition for Nandani, an edge-AIoT platform for livestock health anomaly detection, now running on 40+ farms.
Blaise Pascal Gold Medal
Awarded by the DPS Bokaro Society Foundation for best overall academic and co-curricular performance in Computer Science.
Media
Archive.
The Researchers
DPS Bokaro student innovates ‘Nandini’ AI App to transform cattle health
Prabhat Khabar
Student Innovator Ranks Second at NIT Jamshedpur
VARNANLIVE
New Innovation to help detect faults in buildings
Dainik Bhaskar
Team Qualifies for World Robot Olympiad Nationals
Let’s collaborate.
I’m always open to research initiatives, engineering challenges, and high-impact AI/ML projects.
Let's build something real.
Open to research collaborations, startup opportunities, or just a conversation about AI that actually works in the real world.
Send me a message
"The best technology isn't the most advanced.
It's the one that actually reaches the people who need it most."
— Sarvagya Singh